
Binary Filter Parameters
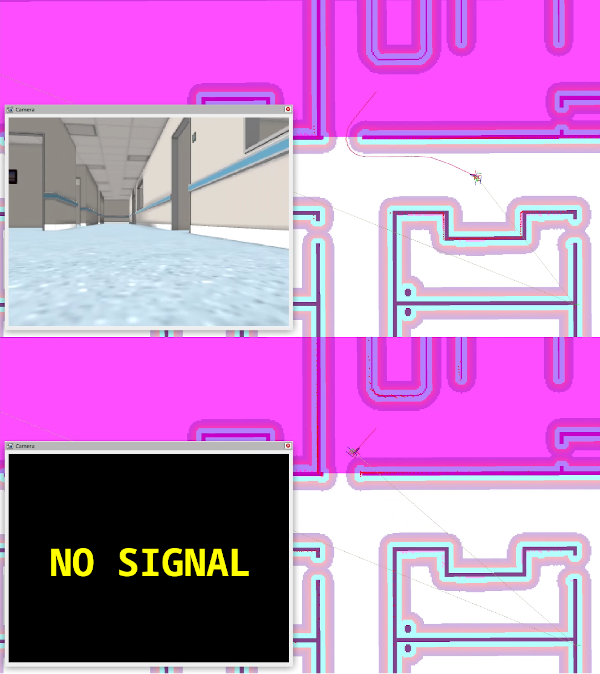
Binary Filter - is a Costmap Filter that publishes a boolean topic, flipping binary state when the encoded filter space value (corresponding to the filter mask point where the robot is) is higher than given threshold. It then flips back when lower or equal.
Filter space value is being calculated as: Fv = base + multiplier * mask_value, where base and multiplier are being published in a filter info by Costmap Filter Info Server. The example of usage are include: camera operating on/off to turn off cameras in sensitive areas, headlights switch on/off for moving indoors to outdoors, smart house light triggering, etc.
<filter name>: is the corresponding plugin name selected for this type.
<filter name>.enabled
- Type:
boolDefault:true -
Whether it is enabled.
<filter name>.filter_info_topic
- Type:
stringDefault:N/A -
Name of the incoming CostmapFilterInfo topic having filter-related information. Published by Costmap Filter Info Server along with filter mask topic. For more details about Map and Costmap Filter Info servers configuration please refer to the Map Server configuration page.
<filter name>.transform_tolerance
- Type:
doubleDefault:0.1 -
Time with which to post-date the transform that is published, to indicate that this transform is valid into the future. Used when filter mask and current costmap layer are in different frames.
<filter name>.default_state
- Type:
boolDefault:false -
Default state of binary filter.
<filter name>.binary_state_topic
- Type:
stringDefault:"binary_state" -
Topic of
std_msgs::msg::Booltype to publish binary filter state to.
<filter name>.flip_threshold
- Type:
doubleDefault:50.0 -
Threshold for binary state flipping. Filter values higher than this threshold, will set binary state to non-default.
Example
global_costmap:
  global_costmap:
    ros__parameters:
    ...
    plugins: ["static_layer", "obstacle_layer", "inflation_layer"]
    filters: ["binary_filter"]
    ...
    binary_filter:
      plugin: "nav2_costmap_2d::BinaryFilter"
      enabled: True
      filter_info_topic: "/costmap_filter_info"
      transform_tolerance: 0.1
      default_state: False
      binary_state_topic: "/binary_state"
      flip_threshold: 50.0