Asymmetric Inflation Layer Parameters
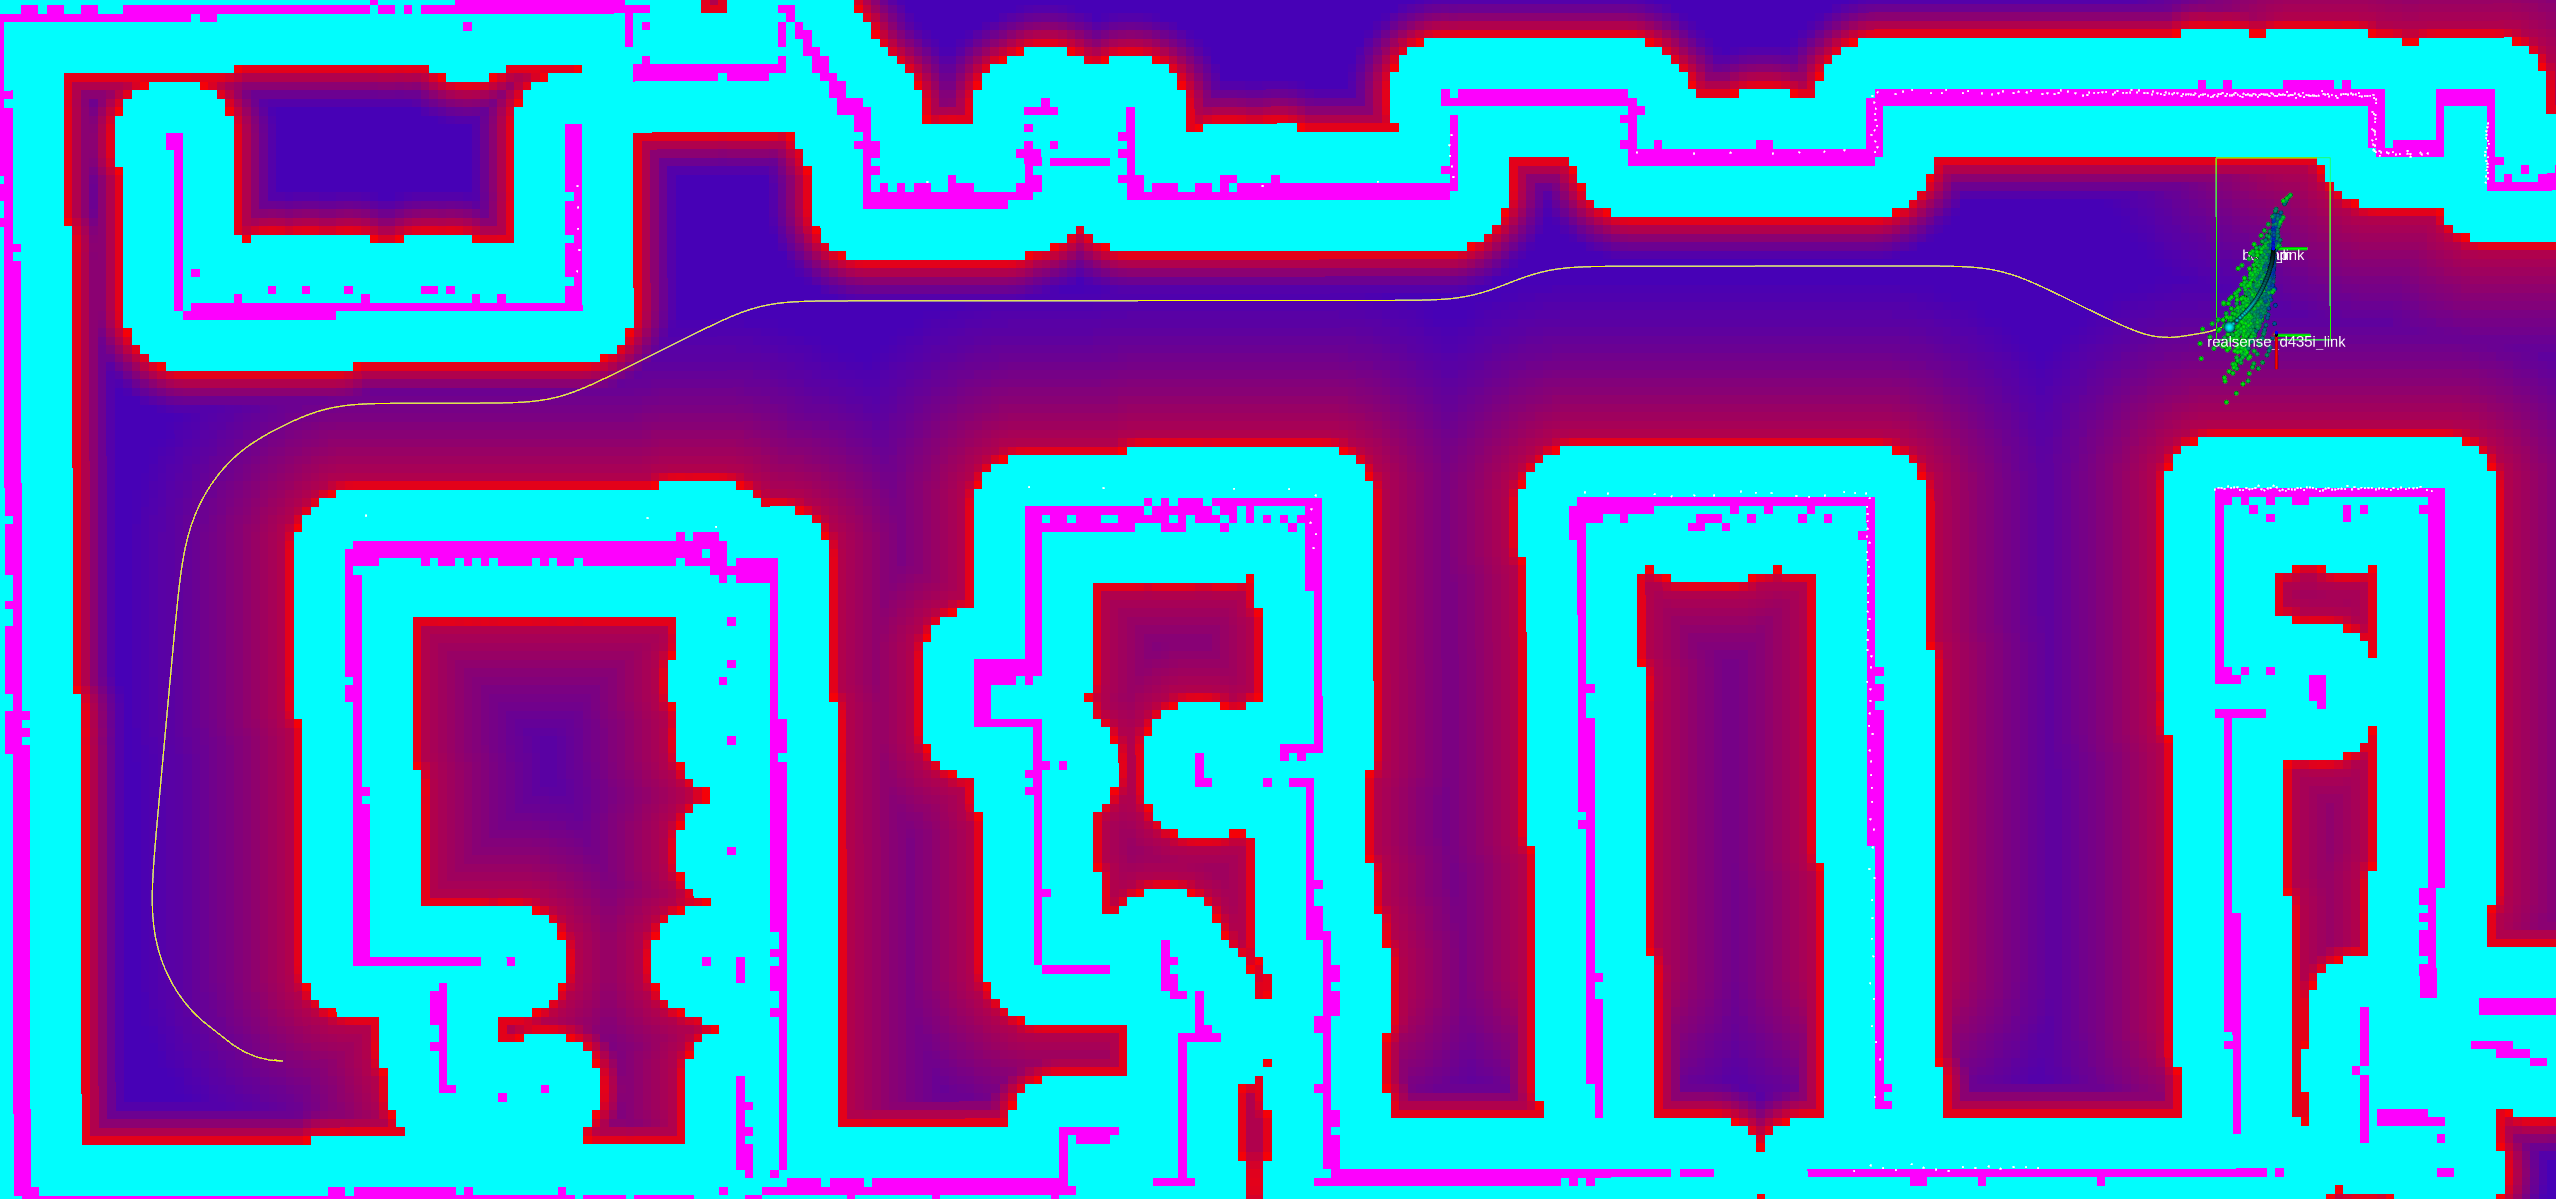
This layer implements an asymmetric variant of the inflation layer, by scaling inflation costs based on the planned path to incentivize left- or right-hand navigation.
<asymmetric inflation layer> is the corresponding plugin name selected for this type.
<asymmetric inflation layer>.enabled
- Type:
boolDefault:true -
Whether it is enabled.
<asymmetric inflation layer>.inflation_radius
- Type:
doubleDefault:2.0 -
Radius to inflate costmap around lethal obstacles.
<asymmetric inflation layer>.cost_scaling_factor_left
- Type:
doubleDefault:4.0 -
Decay factor across inflation radius for obstacles on the left side of the path.
<asymmetric inflation layer>.cost_scaling_factor_right
- Type:
doubleDefault:4.0 -
Decay factor across inflation radius for obstacles on the right side of the path.
<asymmetric inflation layer>.inflate_around_unknown
- Type:
boolDefault:false -
Whether to treat unknown cells as lethal for inflation purposes.
<asymmetric inflation layer>.plan_topic
- Type:
stringDefault:"plan" -
Topic on which to receive the global path (
nav_msgs/msg/Path).
<asymmetric inflation layer>.goal_distance_threshold
- Type:
doubleDefault:1.5 -
Distance to the goal (m) below which asymmetric inflation is disabled.
This prevents oscillations when the robot is approaching the target pose.
Example
global_costmap:
  ros__parameters:
    update_frequency: 10.0
    publish_frequency: 10.0
    global_frame: map
    robot_base_frame: base_link
    footprint: "[ [0.525, 0.325], [0.525, -0.325], [-0.525, -0.325], [-0.525, 0.325] ]"
    width: 10
    height: 10
    origin_x: -5.0
    origin_y: -5.0
    resolution: 0.05
    track_unknown_space: false
    plugins: ["static_layer", "asymmetric_inflation_layer"]
    static_layer:
      plugin: "nav2_costmap_2d::StaticLayer"
      map_subscribe_transient_local: True
    asymmetric_inflation_layer:
      plugin: "nav2_costmap_2d::AsymmetricInflationLayer"
      enabled: True
      inflation_radius: 3.0
      cost_scaling_factor_left: 1.0
      cost_scaling_factor_right: 4.0
      inflate_around_unknown: False
      plan_topic: "plan"
      goal_distance_threshold: 1.5