Plugin Container Layer Parameters
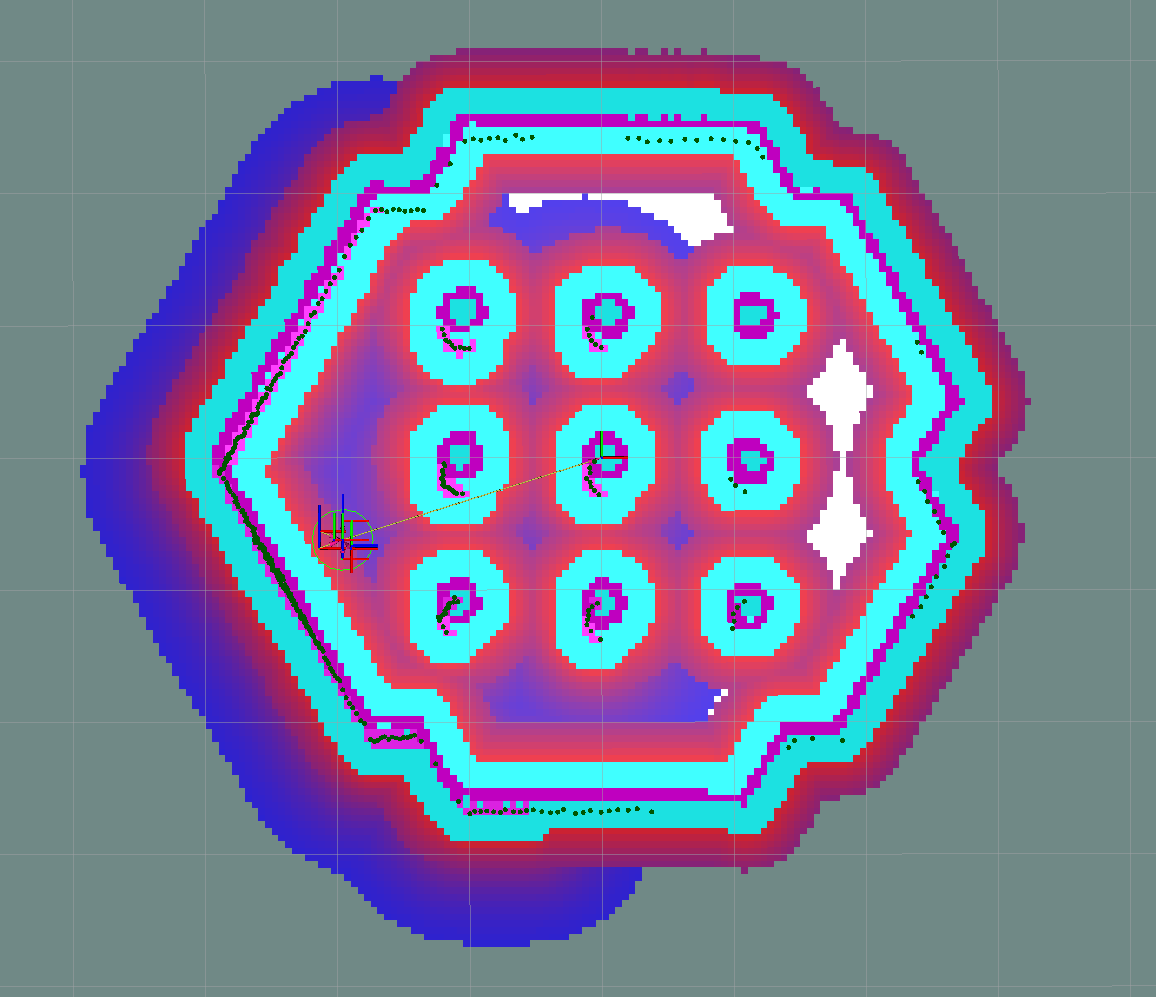
This implements a costmap layer which combines costmap layers within a submap, which can then be integrated with other submaps in the same parent costmap. An example would be the use of different inflation layers for different sensors, objects, or static layers
<plugin container layer> is the corresponding plugin name selected for this type.
<plugin container layer>.enabled
- Type:
boolDefault:true -
Whether it is enabled.
<plugin container layer>.plugins
- Type:
vector<string>Default:[""] -
List of mapped costmap layer names for parameter namespaces and names.
- Note
- Costmap filters are presently unsupported.
Example
global_costmap:
  ros__parameters:
    update_frequency: 1.0
    publish_frequency: 1.0
    global_frame: map
    robot_base_frame: base_link
    robot_radius: 0.22
    resolution: 0.05
    track_unknown_space: true

    plugins: ["plugin_container_static_layer", "plugin_container_obstacle_layer"]

    plugin_container_static_layer:
      plugin: "nav2_costmap_2d::PluginContainerLayer"
      enabled: True
      combination_method: 1
      plugins: ["static_layer", "inflation_layer"]
      static_layer:
        plugin: "nav2_costmap_2d::StaticLayer"
        map_subscribe_transient_local: True
      inflation_layer:
        plugin: "nav2_costmap_2d::InflationLayer"
        cost_scaling_factor: 2.0
        inflation_radius: 0.5

    plugin_container_obstacle_layer:
      plugin: "nav2_costmap_2d::PluginContainerLayer"
      enabled: True
      combination_method: 1
      plugins: ["obstacle_layer", "inflation_layer"]
      obstacle_layer:
        plugin: "nav2_costmap_2d::ObstacleLayer"
        enabled: True
        observation_sources: scan
        scan:
          topic: /scan
          max_obstacle_height: 2.0
          clearing: True
          marking: True
          data_type: "LaserScan"
          raytrace_max_range: 3.0
          raytrace_min_range: 0.0
          obstacle_max_range: 2.5
          obstacle_min_range: 0.0
      inflation_layer:
        plugin: "nav2_costmap_2d::InflationLayer"
        cost_scaling_factor: 3.0
        inflation_radius: 1.0
The above example settings, when applied to the Nav2 turtlebot simulation would give the following costmap on startup