Vector Object Server
The Vector Object Server implements a server that puts vector objects (such as polygons and circles) on OccupancyGrid raster map. The output raster map is being published by Vector Object server, and it could be used anywhere in the Nav2 stack or outside it.
The main application of Vector Object server is to output raster maps of polygon objects or regions with existing costmaps of environment, targeting for robot navigation purposes (for example for dynamic obstacles simulation/highlighting, sensors noise removal, black-out areas on maps, synthetic testing purposes, and much more). Rather than rastering vector objects each iteration or at run-time, it is done one-time on startup, and served to costmap layers or other consumers improving performance. A typical setup model for this is a Nav2 stack with Costmap Filters enabled, running in conjunction with a Vector Object server, which produces vectorised OccupancyGrid maps as input masks for the Costmap Filters:
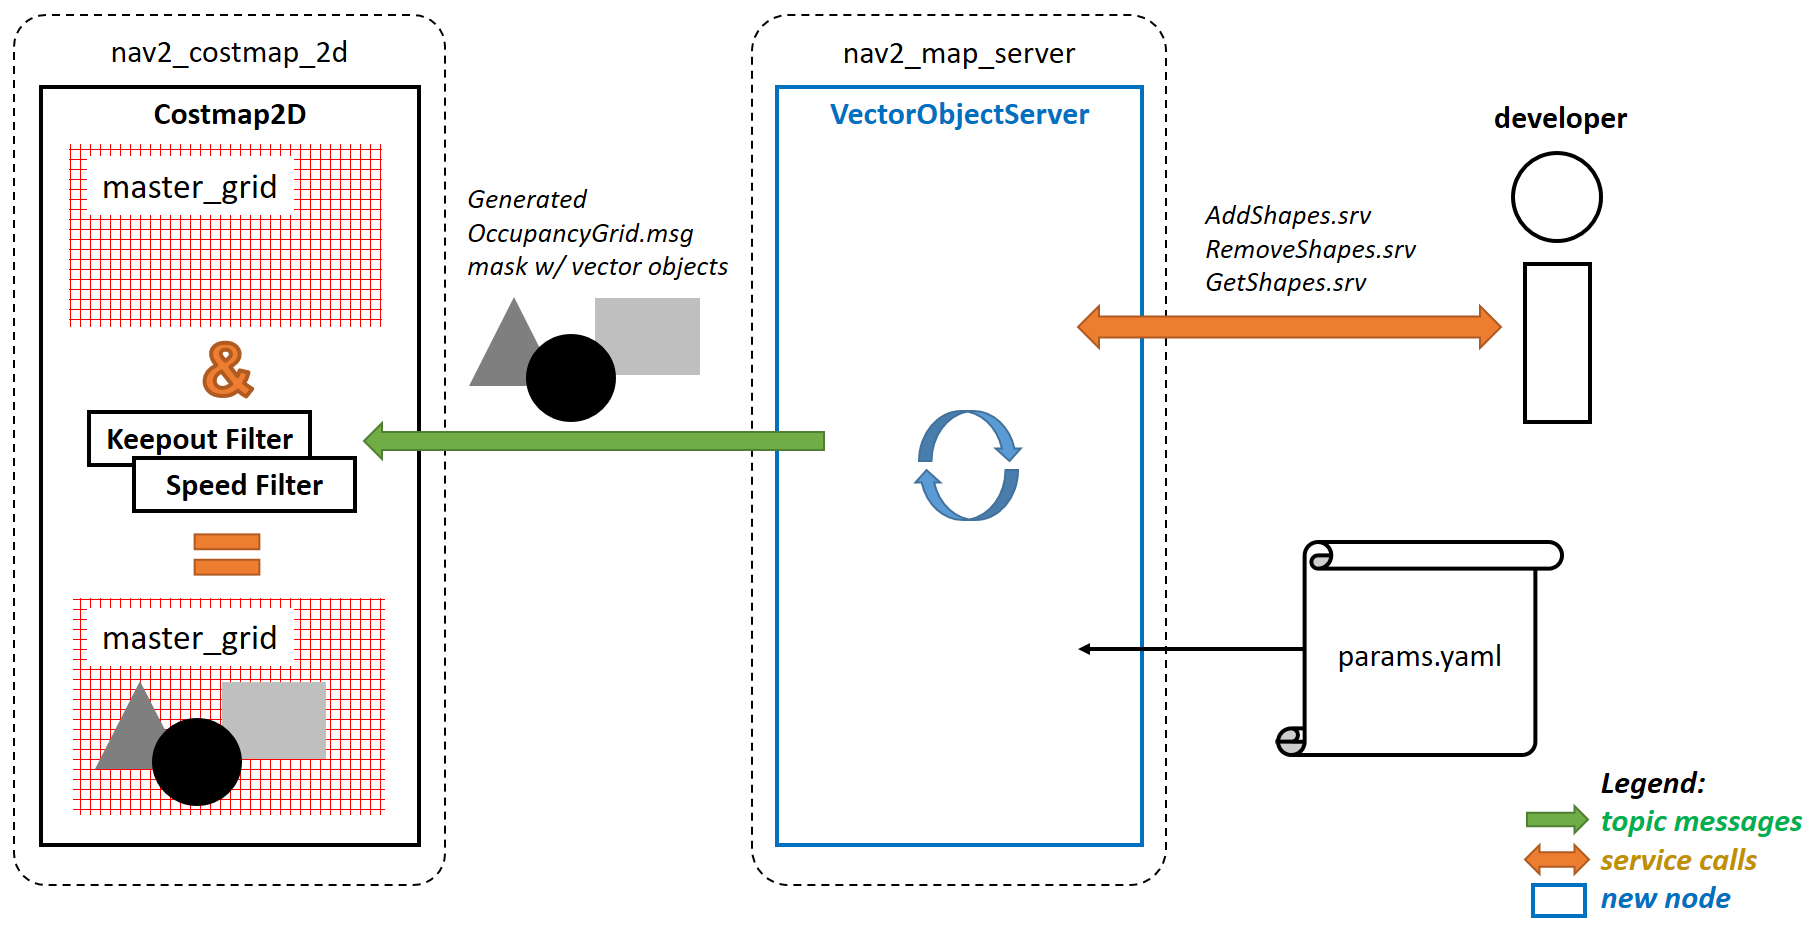
These vector shapes could be added by using ROS input parameters as well as being handled by the following service calls: AddShapes.srv which adds new shapes or modifies existing ones, RemoveShapes.srv which removes any or all shapes from the map GetShapes.srv which returns all shapes on the map.
Each vector shape is being handled by its unique_identifier_msgs/UUID. Developers can choose whether to specify it manually for a new shape, or have it generated automatically by the Vector Object server. The UUID can always be obtained by making a GetShapes.srv request and getting the response with all shapes' UUIDs and their properties.
The Vector Object server places shapes on the map. Each vector object has its own value in the range from {-1}, [0..100], which matches the OccupancyGrid values. Vector objects can be overlapped with each other by using one of the global overlapping rules: (a) sequential overlapping in the same order as vector objects arrived on the server, or (b) taking the maximum / minimum value from all vector objects and the map background (if it is known).
This page describes all the configuration parameters of the Vector Object server. For more information on how to navigate with your own Vector Object server, please refer to the Navigating with Vector Objects tutorial.
Features
- The following vector shapes are currently supported for placing on a map:
- Polygons
- Circles
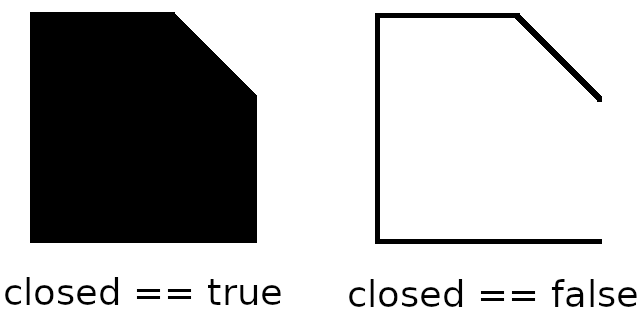
- Polygons can be filled with any value or drawn as a polygonal chain, if it is not supposed to be a closed shape:
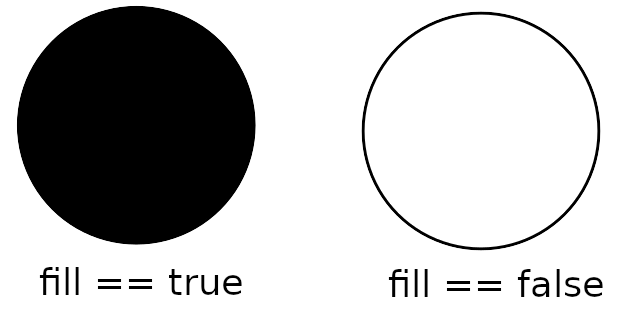
- Circles can be filled with any value or drawn without any fill (only the circle boundary is placed on the map):
- Vector shapes could be set once during the Vector Object server startup as ROS-parameters, and added/modified/removed over the time using the following service calls:
AddShapes.srv: adds new shapes or modifies existing onesRemoveShapes.srv: removes any or all shapes from the mapGetShapes.srv: gets all shapes and their properties
- Vector shapes are being identified by their UUID (
unique_identifier_msgs/UUID), which is generated automatically for a new shape, or could be given manually by the developer. - Vector shapes can be placed in any frame:
- If at least one of the shapes is set in a different frame than the map, a dynamic update model will be enabled: this shape can move over the time, output map will be published dynamically with a given rate.
- If all shapes are set in the same frame as map, map will be published/updated once: at startup of Vector Object server and on each call of
AddShapes.srvorRemoveShapes.srvto change the shape.
Covered use-cases
Using Vector Object server publishing an output map as input mask to Costmap Filters allows the following example use-cases using polygon, vector representations of areas rather than rastered masks:
- No-access zone
- Speed-restriction areas
- Virtual obstacles on costmap
- Geofence / outer boundary and inner virtual obstacles
- Robot footprint (or any other moving objects) replacement
- Hiding some areas from costmap
- Sensors noise removal
- Dynamic objects simulation/highlighting
- Other testing purposes
Parameters
map_topic
- Type:
stringDefault:"vo_map" -
Output topic, publishing an OccupancyGrid map with vector objects put on it.
global_frame_id
- Type:
stringDefault:"map" -
The name of the coordinate frame where the map is being published at.
enforce_global_frame_id
- Type:
boolDefault:false -
Enforce the use of the global frame ID for all shapes. Any shape with a non-empty frame ID, different than the global frame ID, will lead to failure. This will also disable the creation of the TF listener.
resolution
- Type:
doubleDefault:0.05 -
Output map resolution in meters.
default_value
- Type:
intDefault:-1(unknown) -
Default OccupancyGrid value to fill the background of output map with.
overlay_type
- Type:
intDefault:0 -
How one vector object to be overlaid with other and the map. The following values are supported:
0(OVERLAY_SEQ): Vector objects are superimposed in the order in which they have arrived.1(OVERLAY_MAX): Maximum value from vector objects and map is being chosen.2(OVERLAY_MIN): Minimum value from vector objects and map is being chosen. Unknown OccupancyGrid value is always being overrode, when it is possible.
update_frequency
- Type:
doubleDefault:1.0 -
Output map update frequency (when dynamic update model is switched-on).
transform_tolerance
- Type:
doubleDefault:0.1 -
Transform tolerance for the case when any of the shapes are placed in different than map's frame.
shapes
- Type:
vector<string>Default:[""] -
List of vector objects (polygons and circles). Empty by-default.
Shapes parameters
<shape_name> - is the corresponding shape name string selected for this vector object.
<shape_name>.type
- Type:
stringDefault:N/A -
Type of vector object shape. Available values are
"polygon"and"circle". Causes an error, if not specialized.
<shape_name>.uuid
- Type:
stringDefault:N/A -
UUID of the shape specified in
12345678-9abc-def0-1234-56789abcdef0format. Parameter is optional and could be skipped: if not specialized, Vector Object server will automatically generate a new one for the shape.
<shape_name>.frame_id
- Type:
stringDefault:"" -
Frame ID of the given shape. Empty value is being treated as map's global frame.
<shape_name>.value
- Type:
intDefault:100(occupied) -
Shape's value to be put on map with.
Parameters applicable for polygons only
<shape_name>.points
- Type:
vector<double>Default:N/A -
Polygon vertices, listed in
[p1.x, p1.y, p2.x, p2.y, p3.x, p3.y, ...]format (e.g.[0.5, 0.5, 0.5, -0.5, -0.5, -0.5, -0.5, 0.5]for the square). Minimum 3 points for a triangle polygon. Causes an error, if not specialized incorrectly (less than 6 or odd number of items in the vector) or not specialized.
<shape_name>.closed
- Type:
boolDefault:true -
Whether the polygon is closed (and filled), or drawn as polygonal chain otherwise.
Parameters applicable for circles only
<shape_name>.center
- Type:
vector<double>Default:N/A -
Center of the circle, listed in
{center.x, center.y}format (e.g.{0.2, 0.3}). Should contain exactly 2 items: X and Y coordinate of the circle's center in a given frame. Otherwise, causes an error.
<shape_name>.radius
- Type:
doubleDefault:N/A -
Circle radius. Causes an error, if less than zero or not specialized.
<shape_name>.fill
- Type:
boolDefault:true -
Whether the circle to be filled with a given value, or drawn only circle's border otherwise.
Example
Here is an example of configuration YAML for the Vector Object server:
vector_object_server:
  ros__parameters:
    map_topic: "vo_map"
    global_frame_id: "map"
    enforce_global_frame_id: False
    resolution: 0.05
    default_value: -1
    overlay_type: 0
    update_frequency: 1.0
    transform_tolerance: 0.1
    shapes: ["Poly", "CircleA", "CircleB"]
    Poly:
      type: "polygon"
      frame_id: "map"
      closed: True
      value: 100
      points: [0.3, 0.3, 0.3, -0.3, 0.0, -0.3, 0.0, 0.3]
    CircleA:
      type: "circle"
      frame_id: "map"
      fill: True
      value: 10
      center: [3.0, 3.0]
      radius: 0.5
      uuid: "7b3f3d7d-135c-4b6c-aca1-7a84d1050505"
    CircleB:
      type: "circle"
      frame_id: "map"
      fill: False
      value: 90
      center: [3.5, 3.5]
      radius: 1.5
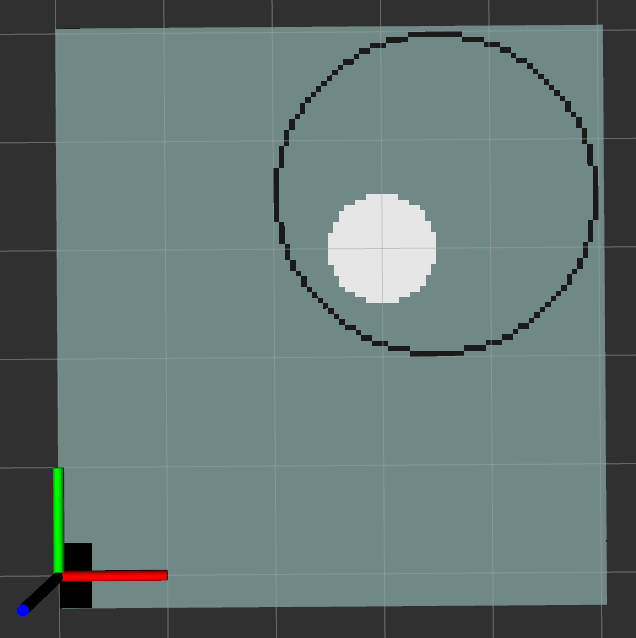
For this, Vector Object server will produce the following map: